Research
Preprints
-
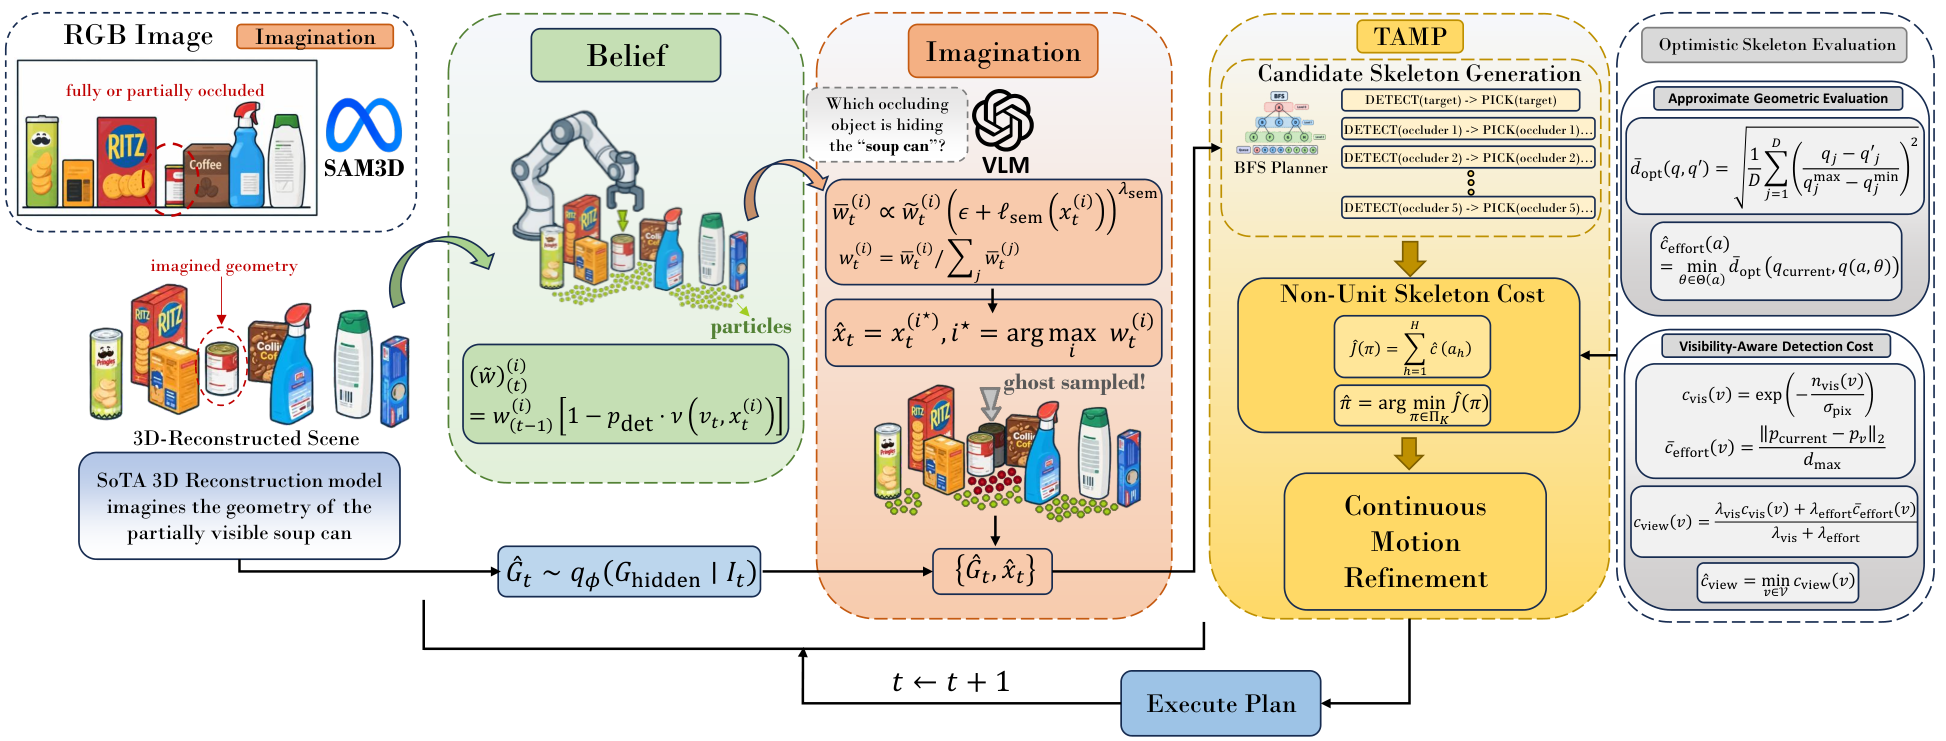
Imagine-TAMP: Imagination-Guided Task and Motion Planning in Partial Observability
A task and motion planning framework that combines vision-language models and imagined 3D scene geometry to reason about hidden objects, evaluate where to look and what to manipulate, and select efficient plans before expensive motion planning.
-
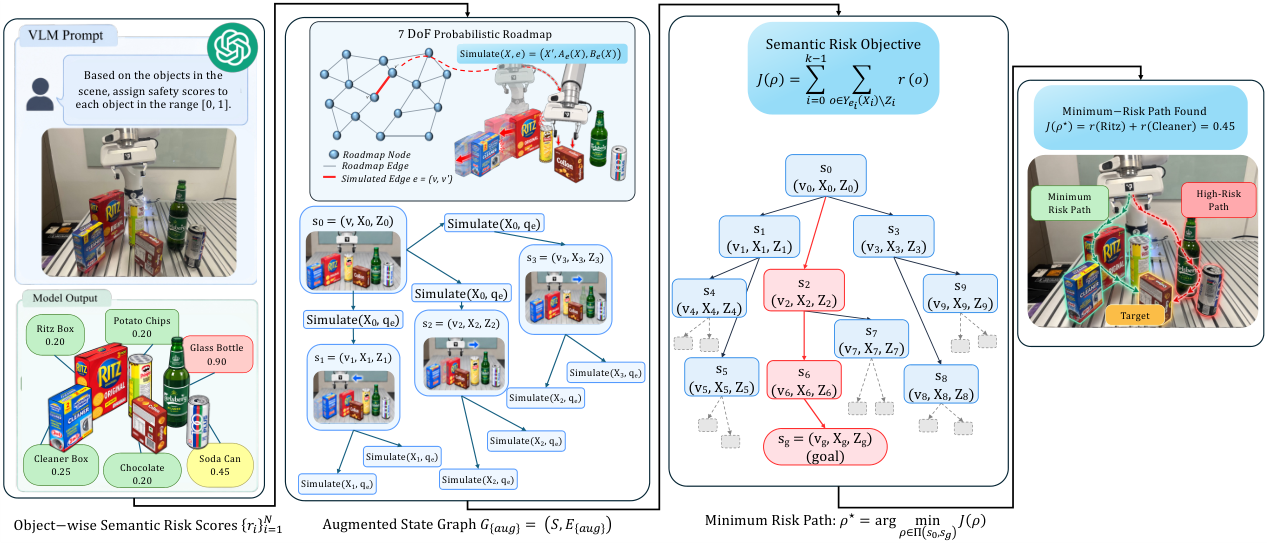
CaSCo: Cascade-Aware Soft-Collision Motion Planning
Enables robots to plan through cluttered environments by reasoning about both direct collisions and their cascading effects, finding paths that minimize the total risk of disturbing surrounding objects using scene semantics from a VLM.